From sensing the environment to understanding the terrain.
Fusing multimodal sensory inputs — including depth vision, LiDAR, and proprioceptive feedback — with an AI-driven World Model, the system continuously extracts terrain structure, obstacle distribution, and robot motion states, delivering reliable environmental intelligence for stable control in complex scenarios.
- Enabling the robot to autonomously adjust locomotion strategies based on the scenario.
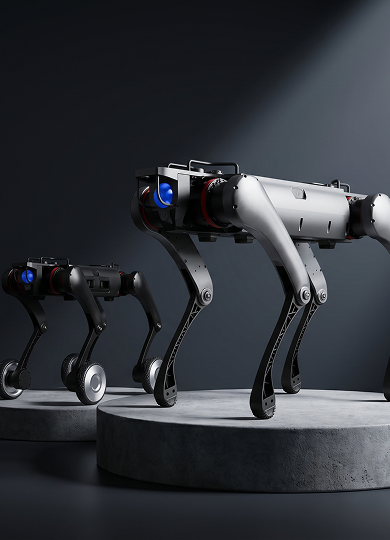
- Leveraging reinforcement learning, Mixture of Experts (MoE), and cross-attention mechanisms — integrating real-time perception with historical motion data — the robot adapts to varying terrains, speeds, postures, and payload conditions, maintaining stable and agile performance across quadruped walking, wheel-legged motion, and multi-mode posture control.