Full-Stack Open Ecosystem
Complete SDK development manuals, STP 3D models, and maintenance documentation — supporting high-level and low-level development.


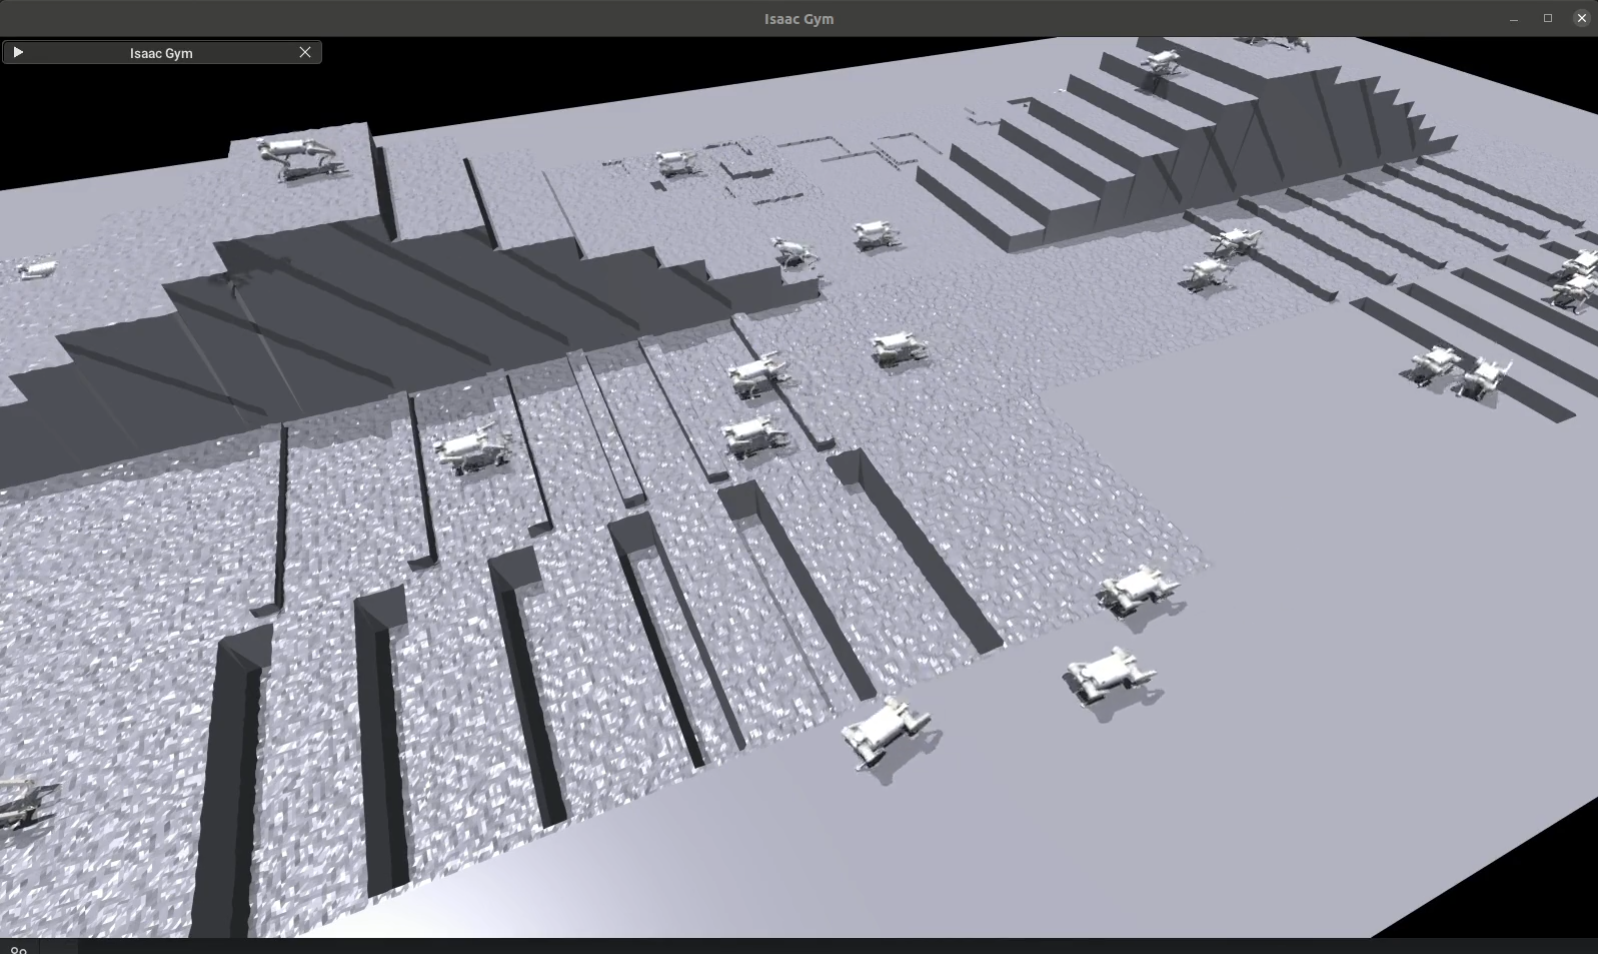
The LINXAI Research & Education Edition quadruped robot features a full-stack open ecosystem, simulation environment support, and rapid iteration capabilities. The robot provides complete SDK development manuals, STP 3D models, and maintenance documentation — supporting both high-level and low-level development. The proprietary SVIP algorithm reduces training time from 100 hours to just 3 hours.
As an open platform tool, LINXAI delivers complete software and hardware interfaces with simulation support — empowering university teaching and algorithm validation. Its full-stack open ecosystem, standardized interfaces, and efficient algorithm iteration capabilities significantly lower R&D barriers, offering a reliable physical platform for cutting-edge research in motion control, multi-robot coordination, and related fields.
Provides a complete quadruped robot hardware platform with development documentation — supporting university courses in motion control, computer vision, embedded systems, and other laboratory curricula.
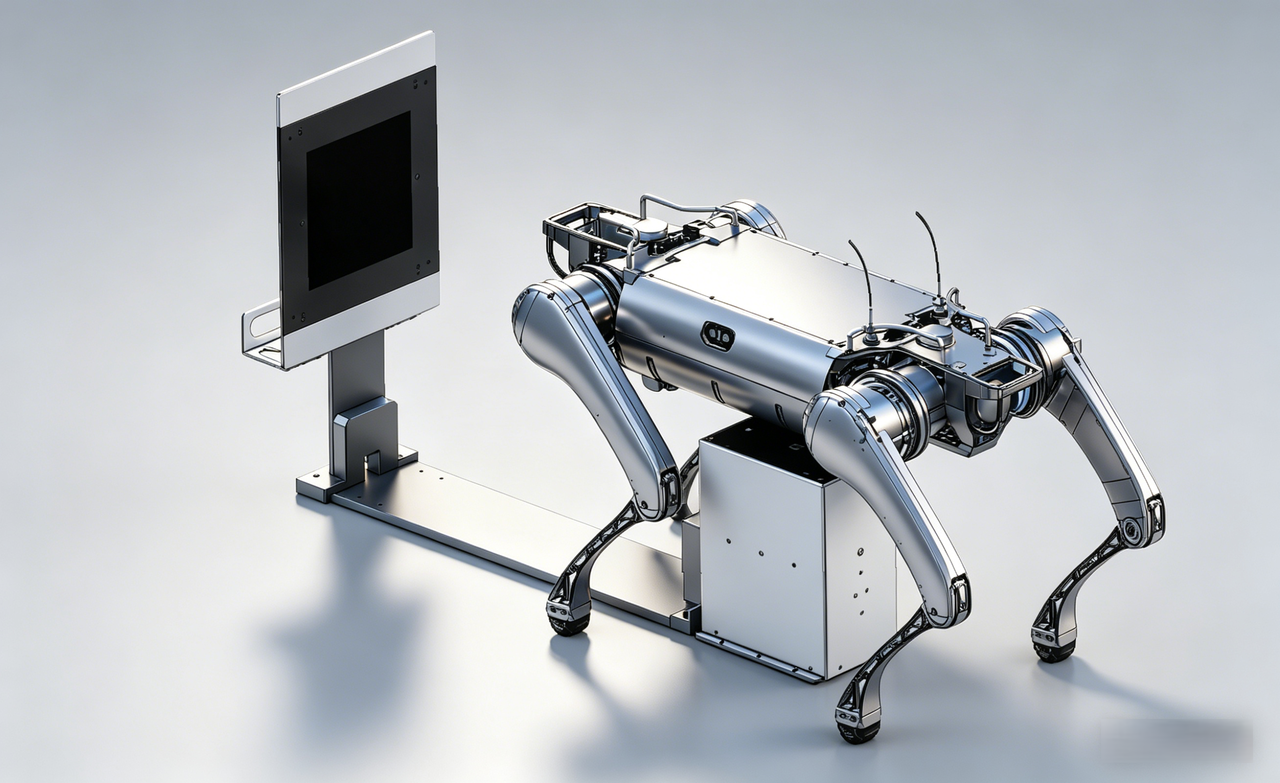
The LINXAI Research & Education Edition quadruped robot delivers a full-stack open ecosystem, simulation environment support, and rapid iteration capabilities. It provides complete SDK development manuals, STP 3D models, and maintenance documentation — supporting both high-level and low-level development. The proprietary SVIP algorithm reduces training time from 100 hours to just 3 hours.